I don’t think you’re ready for this jellyfish-inspired robot that can clean the ocean floor
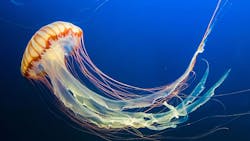
Is there anything more captivating than watching a jellyfish slowly propel itself through the water? I could spend hours at an aquarium watching these majestic creatures dance back and forth. But jellyfish might be more vital to the health and wellness of our oceans than I could have ever imagined. These enticing invertebrates might be the solution to our oceanic pollution problems. No, I’m not suggesting that we arm jellyfish with cleaning supplies and tell them to get to work. These creatures’ unique design, however, is inspiring makers and designers throughout the world as they engineer new ways to remove garbage from the water.
Roboticists at the Max Planck Institute for Intelligent Systems (MPI-IS) in Stuttgart, Germany, have taken inspiration from jellyfish and engineered an underwater robot to collect waste from the bottom of the ocean. The team published their finding in Scientific Advances. The paper, “A versatile jellyfish-like robotic platform for effective underwater propulsion and manipulation,” outlines how their 16-cm-diameter, noise-free prototype can be used to manipulate objects beneath the water’s surface without disturbing nearby species. The machine, dubbed the HASEL jellyfish robot, is approximately the same size as an adult Aurelia aurita also known as the moon jellyfish. According to the research team, the robot is powered by a combination of hydraulically amplified self-healing electrostatic (HASEL) actuators and a hybrid structure of rigid and soft components. The robot, which uses fluid flow to propel itself, has an against-gravity speed of up to 6.1 cm/s and only requires 100 mW of power. Unlike other comparable robots, the HASEL jellyfish robot can trap objects underneath its body without physical contact.
In an excerpt from the paper, team members note, “Given the design and the individual lappet controllability, the robots introduced here fulfilled diverse underwater functions, such as contact-based and contactless object manipulation, fluid mixing, shape adaptation, and steering, without using any bulky or rigid transmission mechanisms. Next, on top of a single robot design, we demonstrated that a team of these robots could further enhance their object manipulation capabilities. Last, we developed a fully wireless prototype and tested it outdoors; all the power and electronics were integrated onboard. This new noise-free robotic jellyfish platform, along with the demonstrated advances in both propulsion performance and practical functions, will help inspiring the next generation of underwater vehicles for real-world applications.”
Tianlu Wang, a postdoc in the Physical Intelligence Department at MPI-IS and first author on the paper, said, "When a jellyfish swims upwards, it can trap objects along its path as it creates currents around its body. In this way, it can also collect nutrients. Our robot, too, circulates the water around it. This function is useful in collecting objects such as waste particles. It can then transport the litter to the surface, where it can later be recycled. It is also able to collect fragile biological samples such as fish eggs. Meanwhile, there is no negative impact on the surrounding environment. The interaction with aquatic species is gentle and nearly noise-free"
About the Author
 Alexis Gajewski
Senior Content Strategist
Alexis Gajewski is a manufacturing writer and editor with nearly 20 years of experience covering the people, practices, and technologies that keep industrial facilities running. For more than a decade, she served as Senior Content Strategist for Plant Services, creating content for plant managers, engineers, and maintenance professionals on a variety of industrial topics.
During her tenure, Alexis worked to develop the brand’s digital strategy and helped launch and produce Great Question: A Manufacturing Podcast. She also created The Lighter Side of Manufacturing, a weekly blog that explored the inventive and sometimes humorous side of the industry.
Alexis co-founded Influential Women in Manufacturing, a recognition program that honored 49 women in its first two years, earned an industry award for Best Product Launch, and received a proclamation from Illinois Governor JB Pritzker and a commendation from U.S. Senator Tammy Duckworth.
She also led newsroom operations and development at a large media company where she set editorial standards, developed training curriculum, and helped support AI adoption for more than 150 editors across 80+ brands spanning manufacturing, industrial processing, automation, and more.
Additionally, Alexis works as a freelance writer and editor, and her areas of interest include continuous improvement, the skilled workforce, and the role of emerging technology on the plant floor.
Connect with Alexis on LinkedIn